|
I am a final-year undergraduate student majoring in Information Engineering at the Department of Electrical and Electronic Engineering, Southern University of Science and Technology (SUSTech). I am currently a research intern at the World Mind Lab, Hong Kong University of Science and Technology (HKUST), supervised by Prof. Fangneng Zhan and an undergraduate research assistant at the AdaComp Lab, School of Computing, National University of Singapore (Jan 2025 – present), supervised by Prof. David Hsu. Previously, I led a university-funded research project under the RCV Lab, Southern University of Science and Technology (Sep 2024 – Sep 2025), as part of the Climbing Program for Innovation and Research, supervised by Prof. Hong Zhang. My research focuses on scene representation and perception for robotic manipulation. I am interested in developing unified frameworks that combine geometric reconstruction, object detection and tracking, and articulation reconstruction to enable robots to understand and interact with complex environments. |
|
|
|
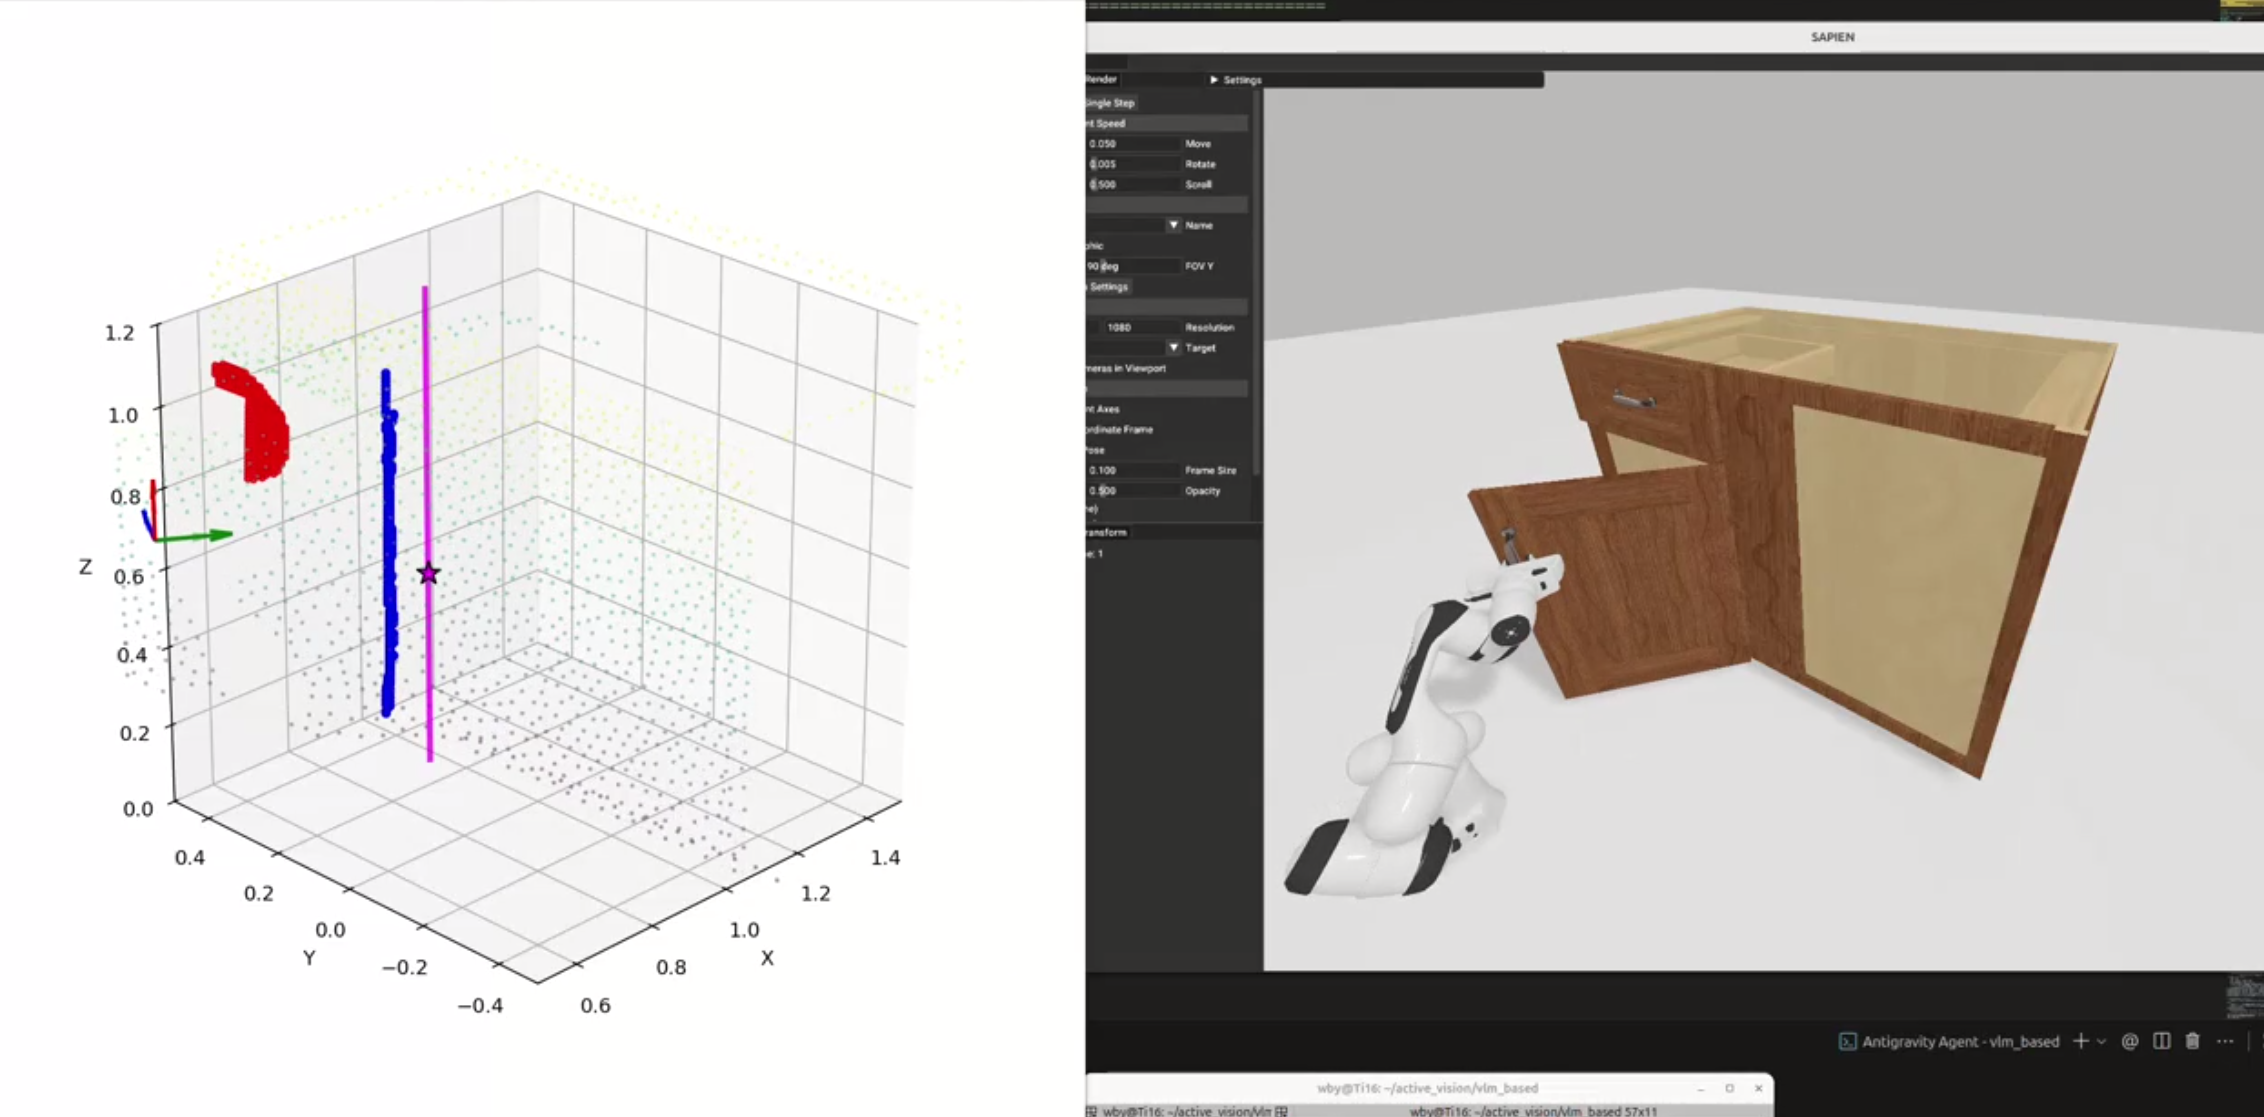
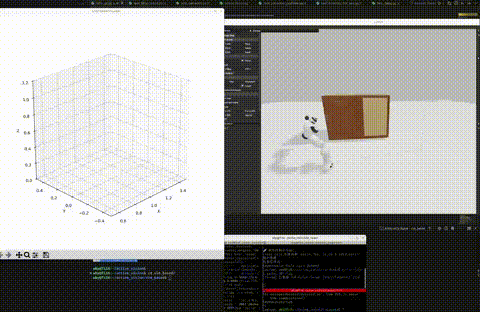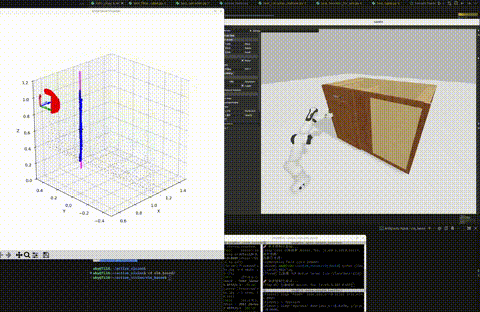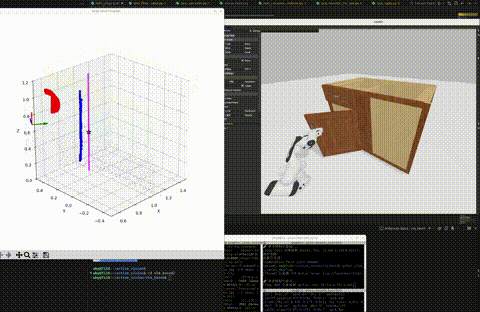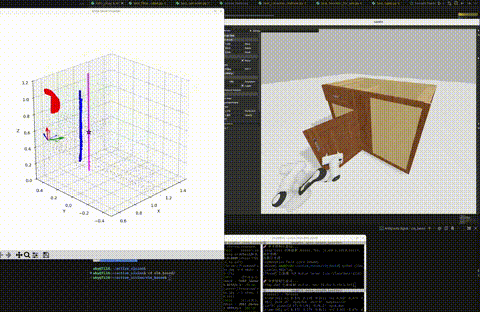
Research Intern, World Mind Lab, HKUST Keywords: Articulated Manipulation, Active Perception Developed a closed-loop articulated manipulation system featuring VLM-based zero-shot planning for articulated manipulation (e.g., operating cabinets). Designed an online screw-parameter refinement strategy that leverages robot kinematic and visual feedback to realign articulation axes in real-time; this active-sensing approach provided critical calibration for concurrent visual reconstruction modules. Code (In progress) |
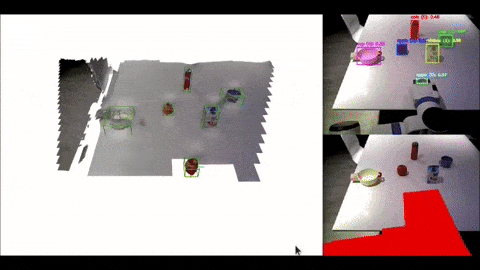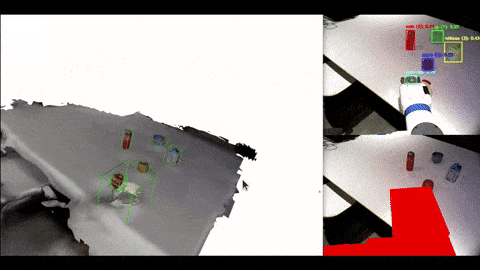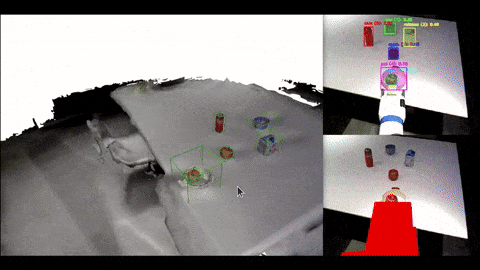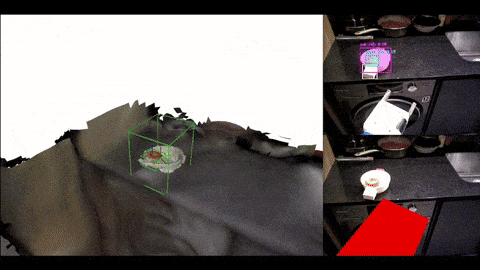
|
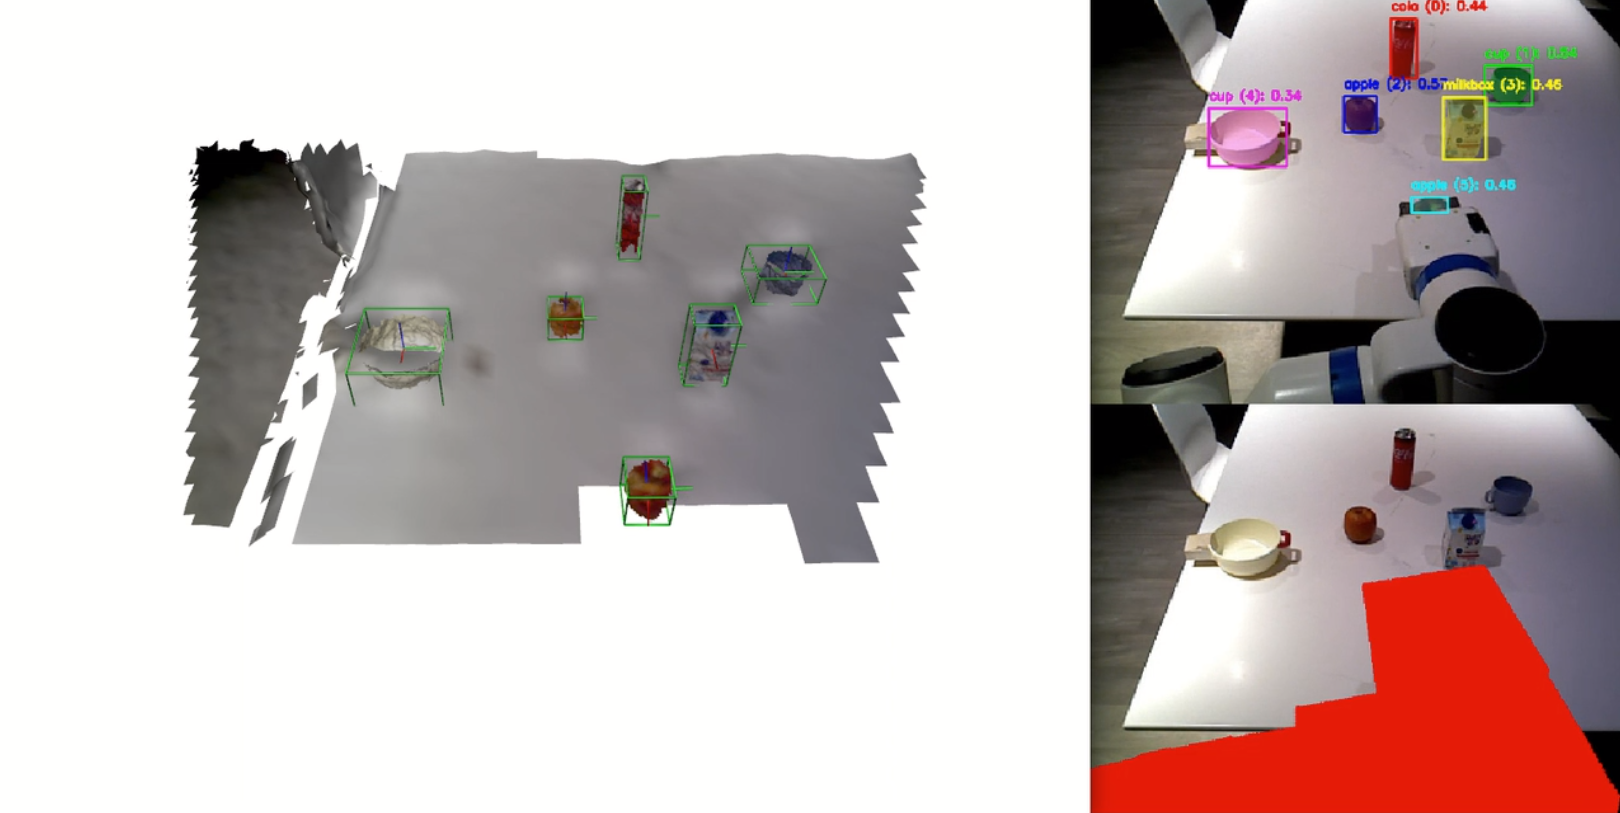
Research Assistant, AdaComp Lab, NUS Keywords: Scene Representation, Object Tracking, Dynamic Environments As a research assistant at the AdaComp Lab, I designed and implemented a real-time robotic perception system that integrates object detection, segmentation, tracking, pose estimation, and geometric reconstruction within a unified scene representation framework. The system leverages manipulator pose feedback to improve robustness in dynamic pose estimation and runs in real time on physical robotic platforms. Demo Video Code (In progress) |
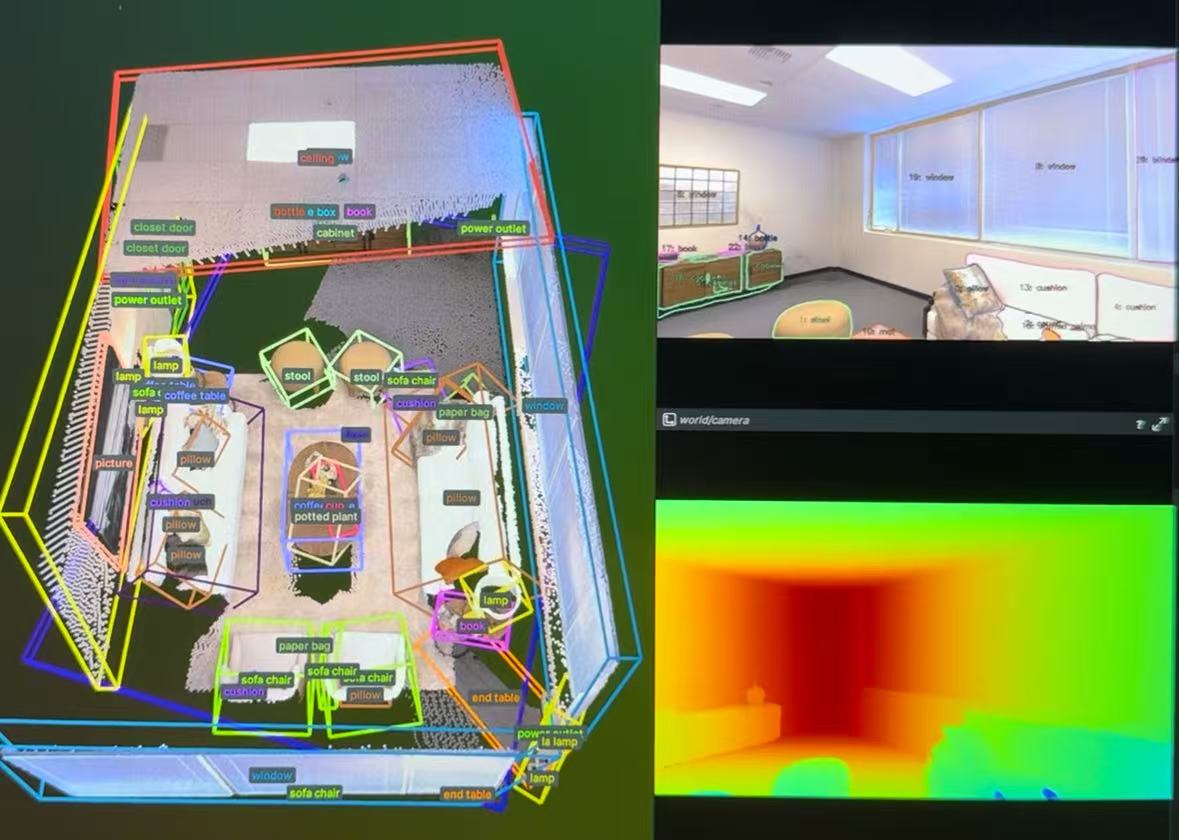
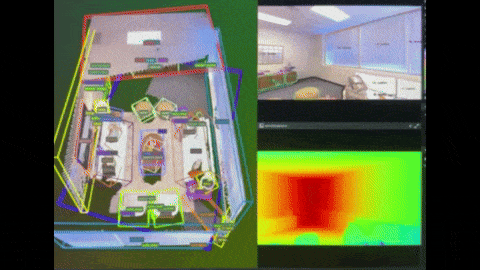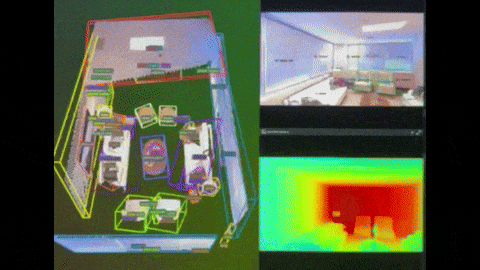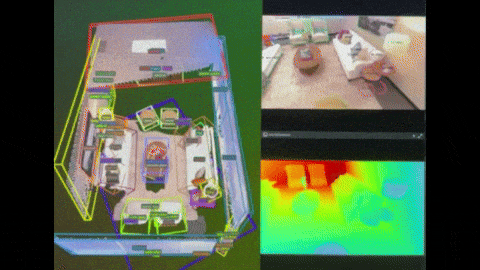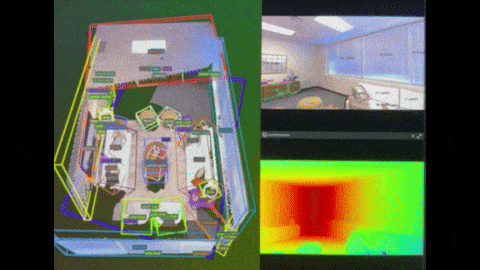
|
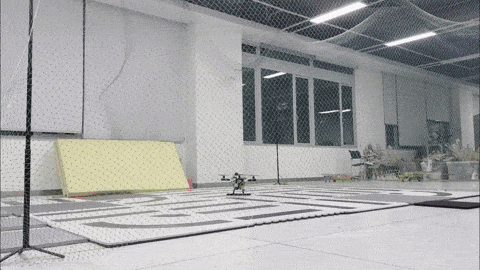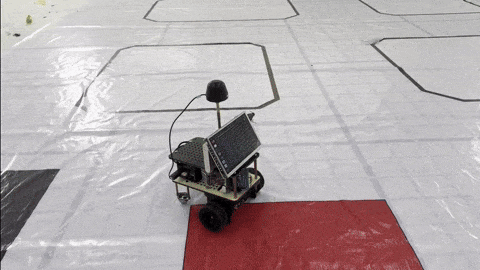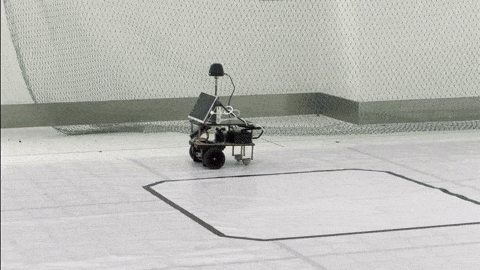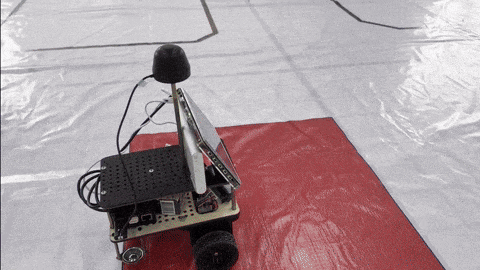
Project Leader, Climbing Program for Innovation and Research, SUSTech Keywords: Scene Understanding, Semantic Mapping As the project leader of a university-funded research program, I was responsible for designing the system architecture and implementing core modules for an autonomous indoor delivery robot, focusing on open-vocabulary semantic mapping and object-level representation to enhance scene understanding and task planning in structured environments. |
|
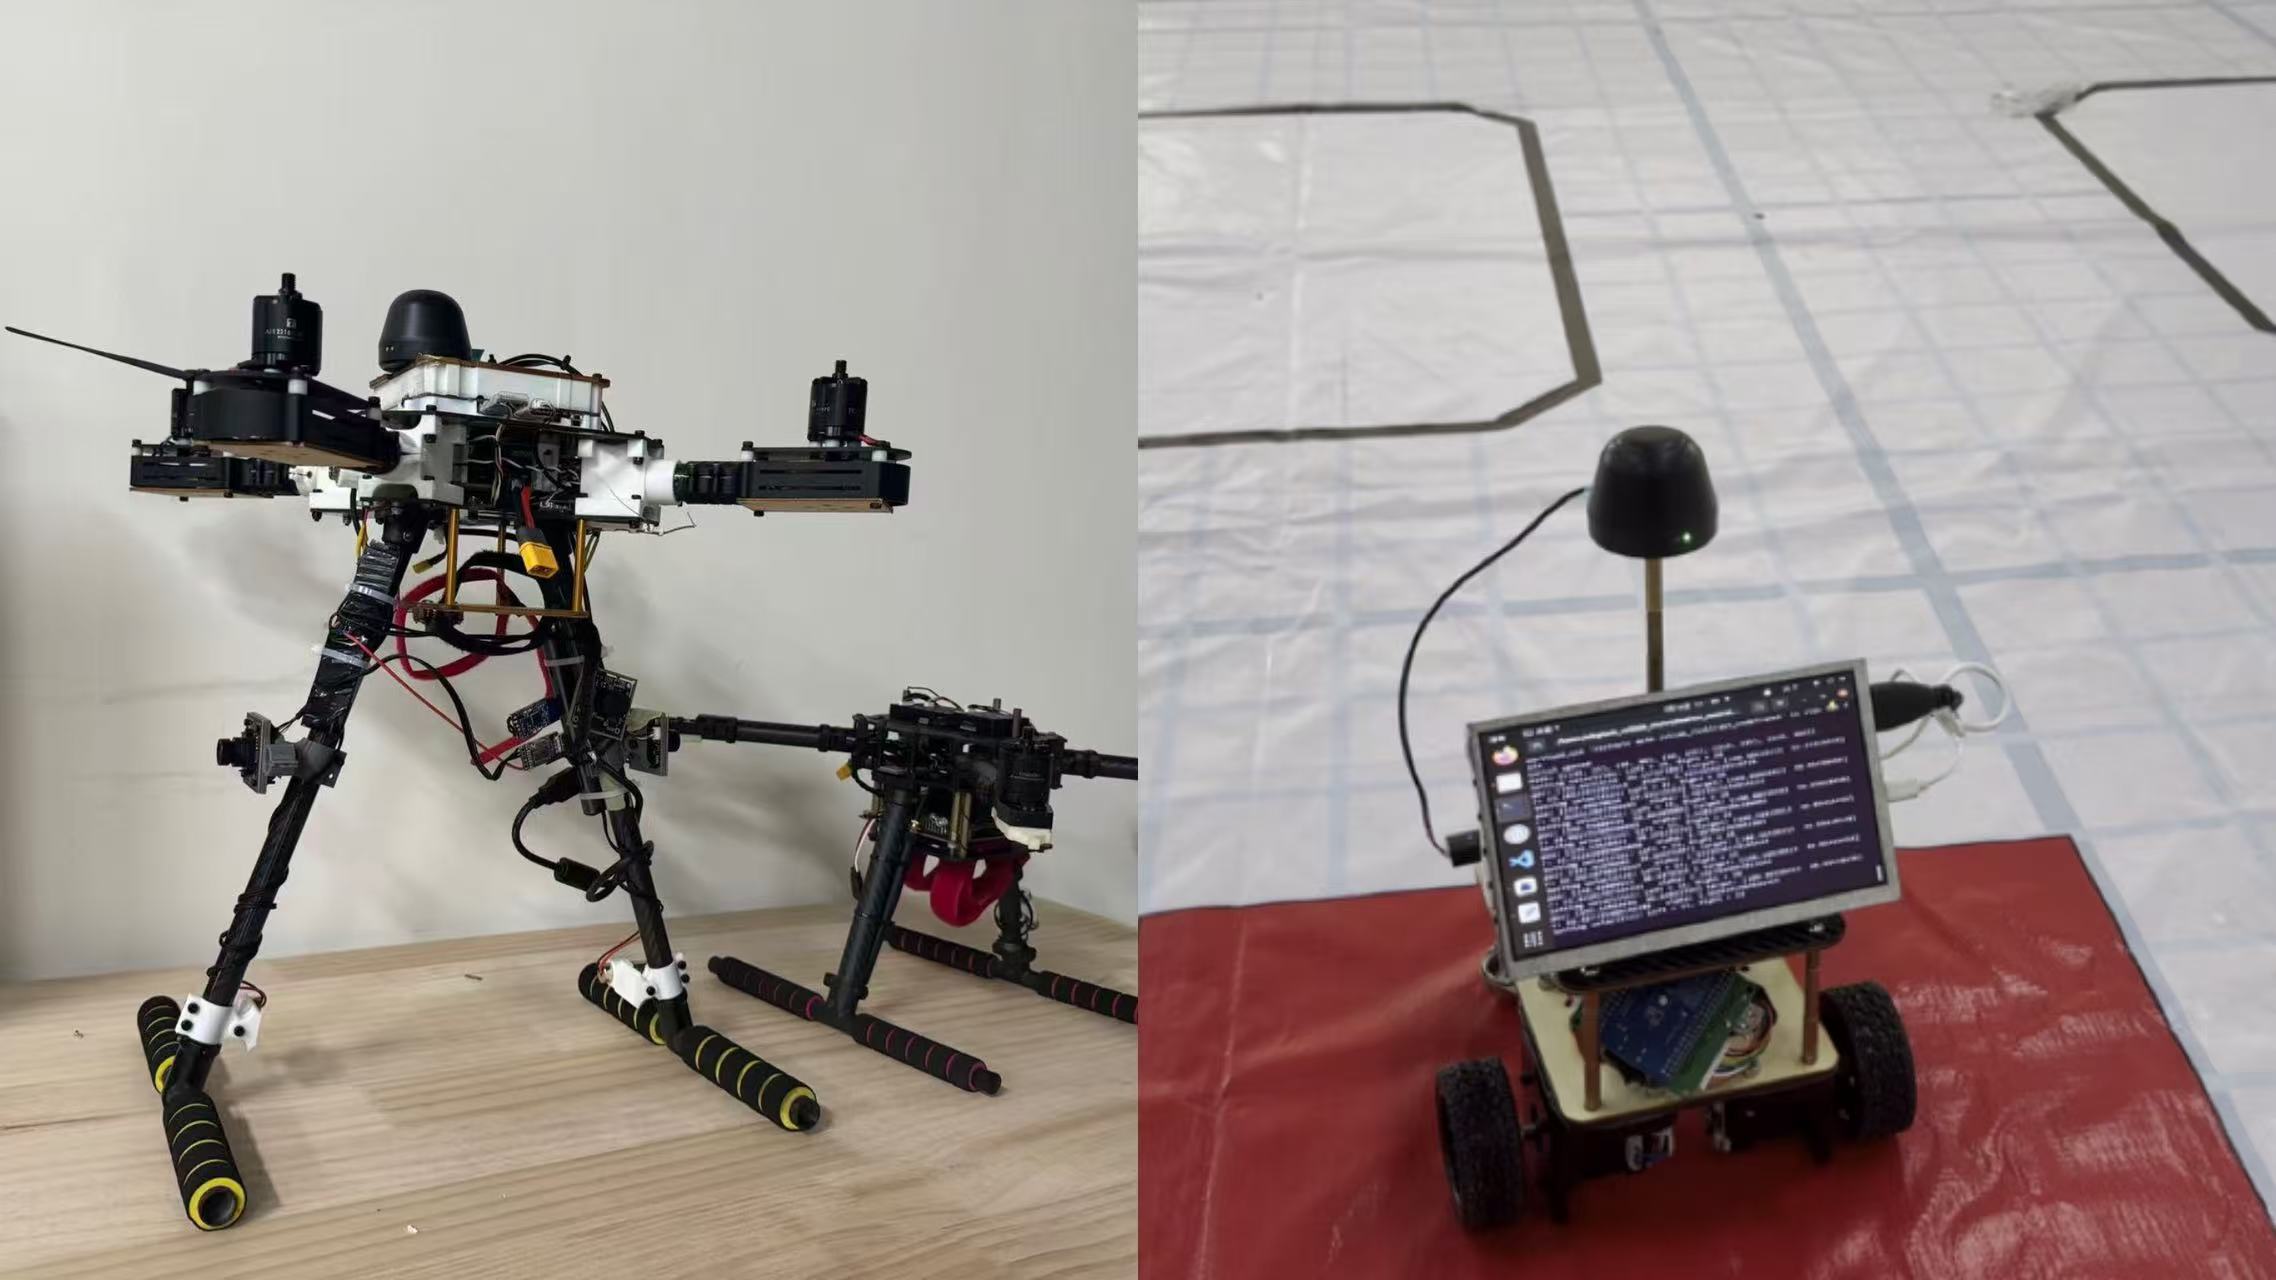
National College Students' Innovation and Entrepreneurship Training Program, SUSTech Keywords: UWB Localization, UAV, Multi-Robot System In this project, I was responsible for developing the UWB-based localization module and implementing motion control for ground robots, enabling precise indoor navigation and coordination with aerial platforms in GPS-denied environments. |
|
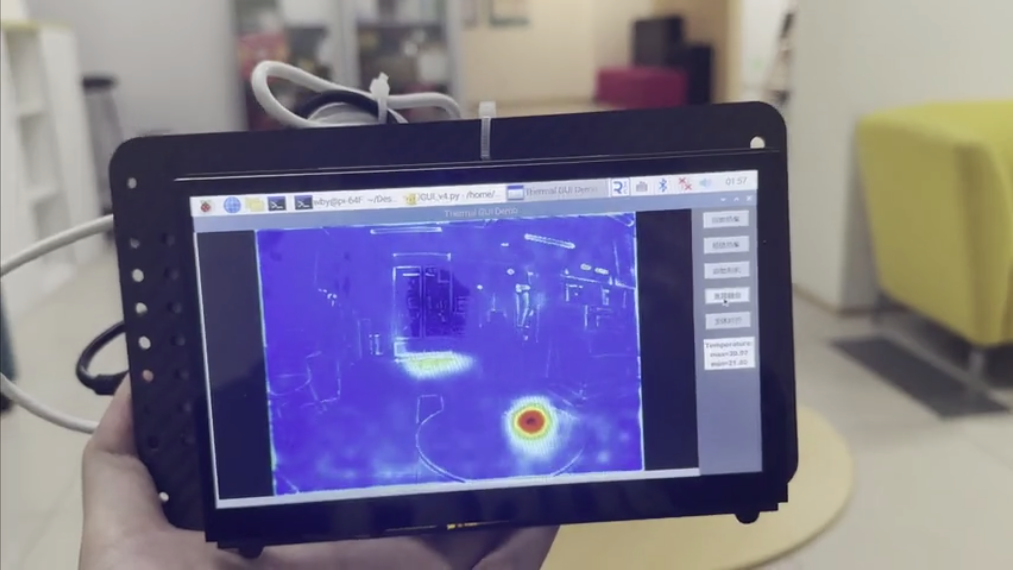
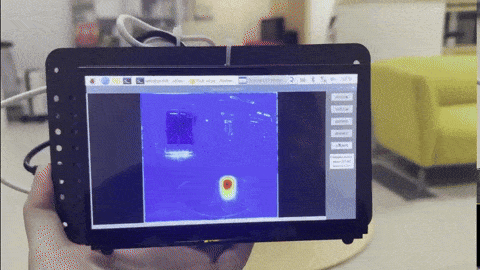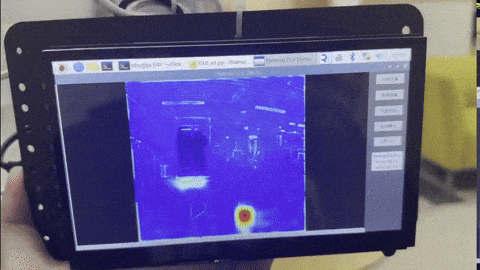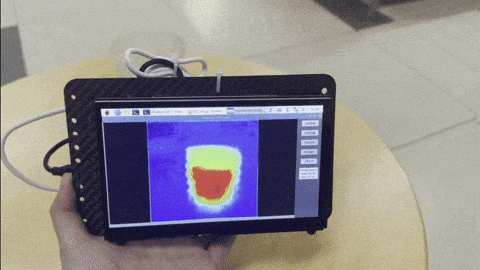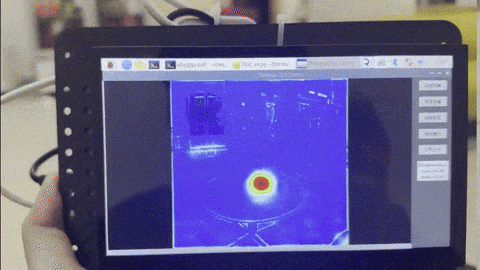
SUSTech EE351 Microcomputer Principles and Microsystems Course Project Keywords: Thermal Imaging, Sensor Fusion In this course project, I designed a dual-spectrum imaging system based on Raspberry Pi 5, fusing visible and thermal images with parallax correction. |
|
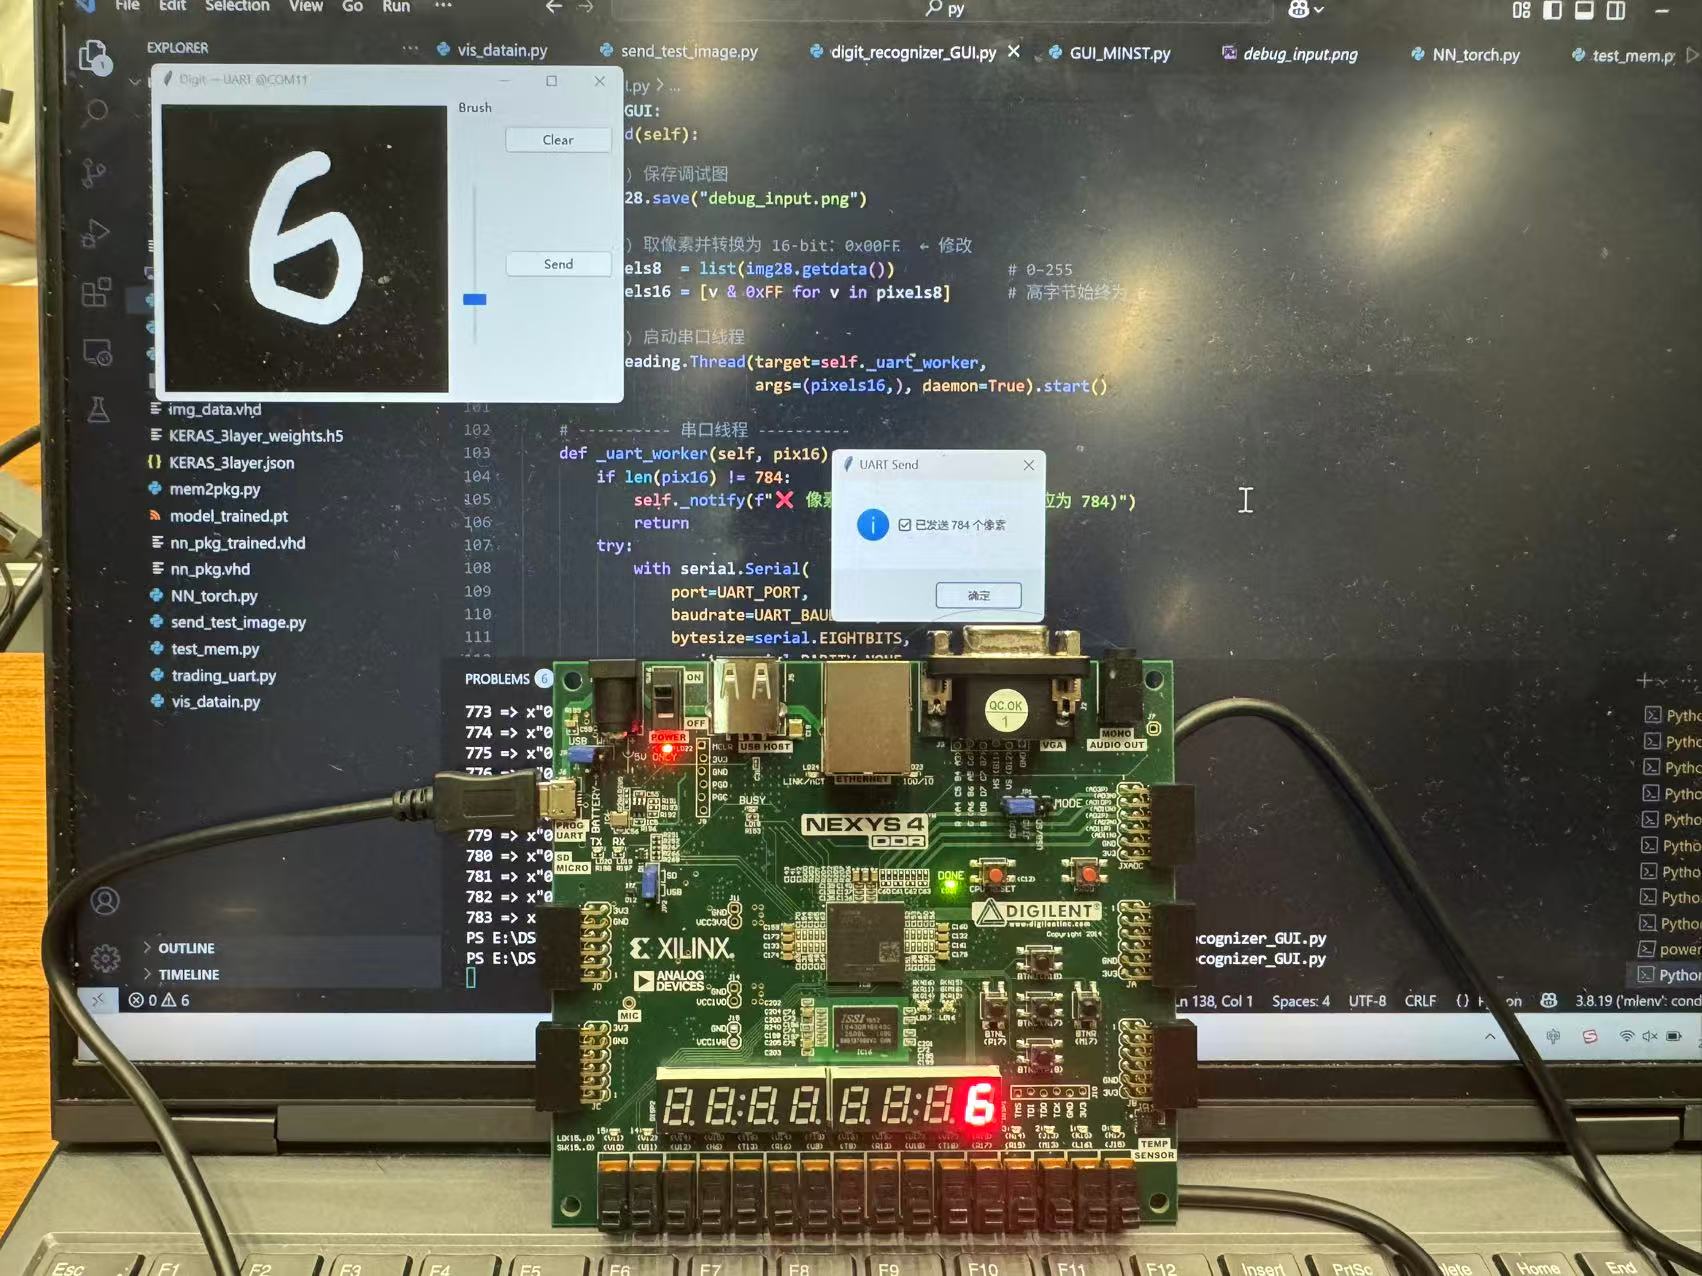
SUSTech EE332 Digital System Design Course Project Keywords: FPGA, Neural Network, Hardware Acceleration In this course project, I implemented a feed-forward neural network on an FPGA for handwritten digit recognition using the MNIST dataset. I designed the hardware architecture in VHDL, including parallel MAC units and pipeline modules, and optimized memory access for efficient on-chip inference acceleration. |
First-Class Academic Scholarship |
Southern University of Science and Technology |
Member of the Wolong Program |
Department of Electrical and Electronic Engineering, SUSTech |
|
Modified version of template from here Last updated: 26 Apr. 2026 |